Biomimetic hairy whiskers for robotic skin tactility
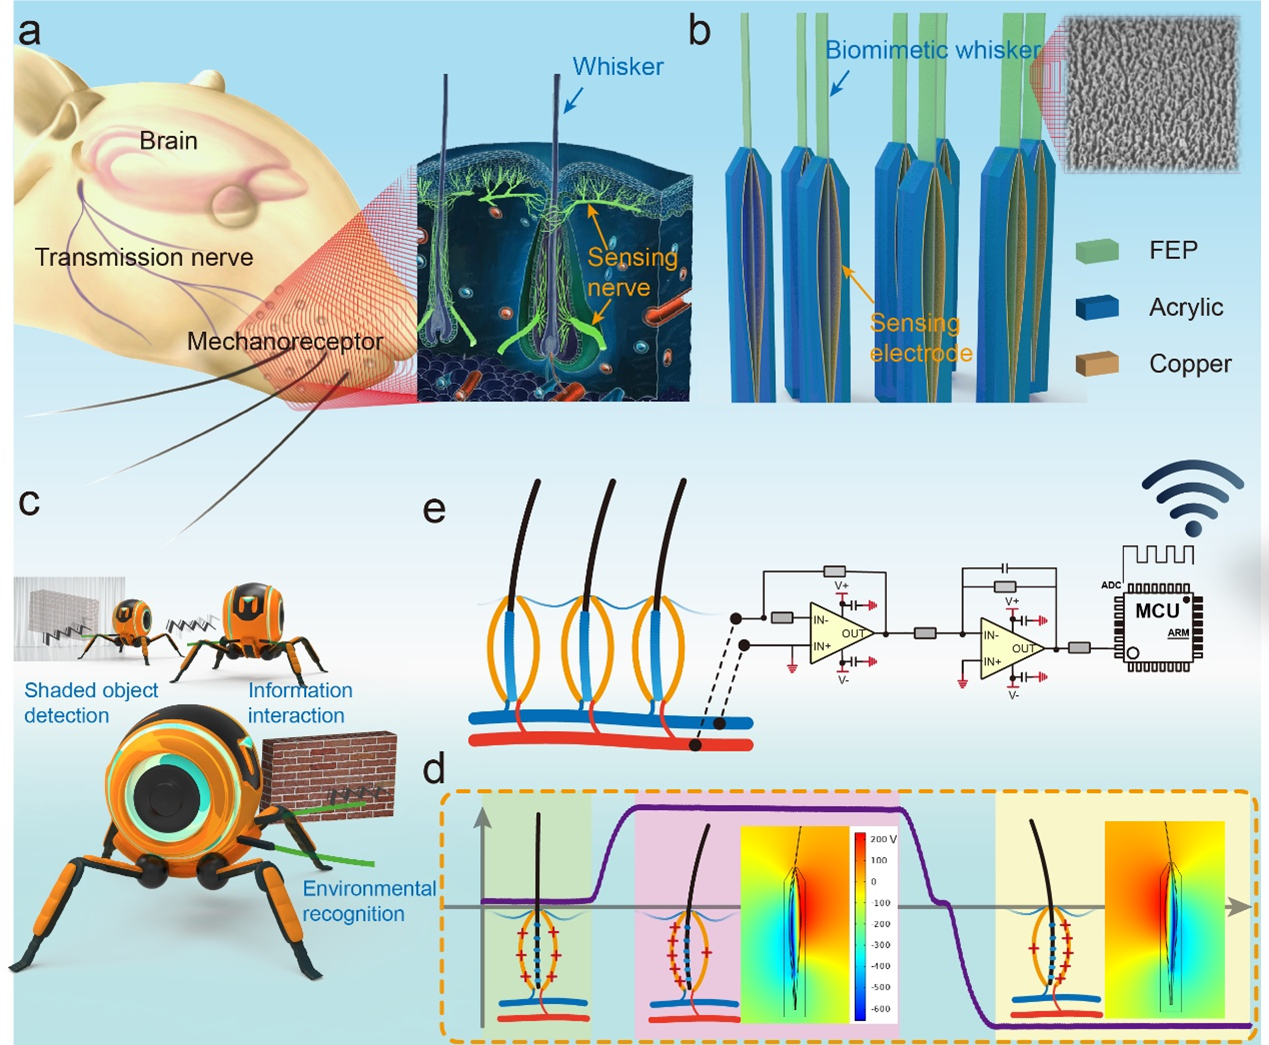
Touching sensing is among the most important sensing capabilities of a human, so is for smart robotics. Current researches on tactile sensors are mainly concentrated on electronic skin, but it is prone to be easily dirtied, damaged, and disturbed after repeated usage, which greatly limits its practical applications in robotics. Here, by mimicking the way that animals explore the environment using hair-based sensors, we designed a bendable biomimetic whisker mechanoreceptor (BWMR) for robotic tactile sensing. Owing to the advantages of triboelectric nanogenerator technology, the BWMR can convert external mechanical stimuli into electrical signals without power supply, which is conducive to its widespread applications in robots. Because of the leverage effect of the whisker, the BWMR can distinguish an exciting force of 1.129 μN by amplifying external weak signals, which can be further improved by increasing the whisker length. Real time sensing has been demonstrated using BWMR for exhibiting its potential for robotic tactile system.